
Imajbox systems combine multifrequency, multi-constellation GNSS receivers with high-end MEMS inertial measurement units and vision to produce precise, continuous and reliable trajectories, even in challenging mobile mapping environments.
Precise and Continuous Trajectory
Imajbox systems rely on GNSS positioning computed from 4 constellations — GPS (United States), Galileo (European Union), GLONASS (Russia), and BeiDou (China) — to determine their location on the Earth’s surface. The receivers we use are especially immune to multipath effects (advanced multipath mitigation), as well as to jamming and spoofing.
Under ideal conditions, signals received from satellite navigation constellations, combined with ground corrections (RTK or PPK — real-time kinematic or post-processed kinematic), make it possible to generate a precise and reliable trajectory for mobile mapping operations.
However, real-world reception conditions are rarely perfect. Dense urban environments (urban canyons), wooded areas, bridges and tunnels can degrade, disrupt or temporarily interrupt GNSS signals.
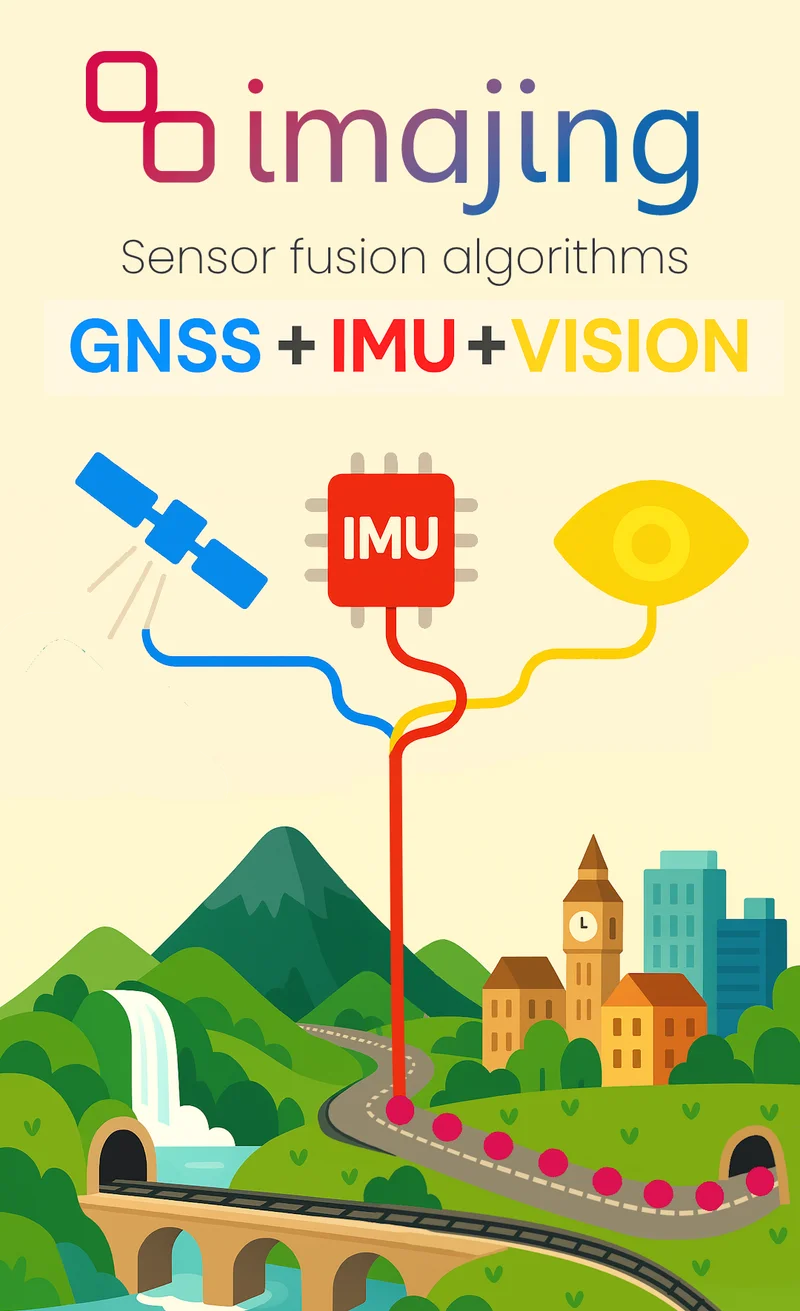
This is precisely where Imajing’s expertise becomes essential. To maintain positioning continuity and minimise accuracy loss, Imajing’s teams have developed advanced multi-sensor fusion algorithms based on extended Kalman filtering, capable of combining GNSS data with measurements from the inertial measurement units integrated into Imajbox systems.
This approach makes it possible to estimate the trajectory even when satellite signals are degraded or temporarily unavailable.
By using tactical-grade inertial measurement units, Imajbox systems can reduce positioning drift, maintain a consistent estimation of movement and provide robust geolocation in constrained environments.
We use information extracted from captured imagery to compute relative displacement from one image to another. This data can be seen as an additional sensor and becomes a new source of information injected into the EKF to strengthen trajectory estimation and improve positioning consistency, for example in highly vibrating situations.
The combination of GNSS, IMU and vision enables the production of precise, continuous and operational mapping data, even under difficult conditions.
Three Complementary Sensors
Provides absolute positioning down to the centimetre using satellite navigation constellations when reception conditions are suitable.
Measures movement, acceleration and orientation to maintain trajectory continuity during GNSS degradation or temporary signal loss.
Uses information extracted from captured imagery as an additional sensor to strengthen trajectory estimation and positioning consistency.
Benefits
Learn how Imajing combines high-precision positioning, imagery and advanced sensor fusion to produce reliable geospatial data in challenging environments.
Contact Imajing